Repository navigation
chore: update autoware repos files for version 1.10.0 - #7364
Conversation


…toware_core to 1.10.0

Signed-off-by: github-actions <github-actions@github.com>
…toware_universe to 0.53.0

Signed-off-by: github-actions <github-actions@github.com>
…toware_launch to 0.53.0

Signed-off-by: github-actions <github-actions@github.com>


|
Thank you for contributing to the Autoware project! 🚧 If your pull request is in progress, switch it to draft mode. Please ensure:
|

|
autowarefoundation/autoware_universe#13518 was needed to run rosbag simulation |
…toware_universe to 0.53.1

Signed-off-by: github-actions <github-actions@github.com>
Humble ChecksPSim v1.10.0_psim-2026-10-20_23.09.03-compressed.mp4Rosbag Replay v1.10.0_rosbag_sim-2026-10-20_23.14.43-compressed.mp4AWSIM: CARLA v1.10.0_carla-2026-10-21_02.19.44-compressed.mp4 |


 xmfcx
left a comment
xmfcx
left a comment
There was a problem hiding this comment.
I tested the 1.10.0 pins from this PR on Jazzy. The planning simulator, rosbag replay and AWSIM demos work. I skipped CARLA for this release.
Planning simulator

Run notes
- Workspace: source build of this PR at
8da95dfeb(autoware_core1.10.0,autoware_universe0.53.1,autoware_launch0.53.0).colcon buildfinished 502 of 502 packages. - Platform: Ubuntu 24.04.5, ROS 2 Jazzy,
RMW_IMPLEMENTATION=rmw_cyclonedds_cpp, RTX 3090 with driver 595.99.02. - Command:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=$HOME/autoware_map/sample-map-planning vehicle_model:=sample_vehicle sensor_model:=sample_sensor_kit - Route: lanelet 143 to lanelet 136, 388 m with two left turns and no traffic lights.
- Result: the route state changed to
ARRIVEDafter 108 s and 387.3 m. The top speed was 4.30 m/s. - The screenshot is from 54 s after engage, at 15 km/h with 193 m left.
- A first route went through virtual traffic light 10001 on lanelet 44. The vehicle stopped at its stop line and waited for a V2I answer, as designed. The planning simulator has no V2I source.
- Not run here: Humble.
These run notes are AI generated.
Rosbag replay simulation

Run notes
- Same workspace and platform as the planning simulator run, with TensorRT
10.13.3.9-1+cuda13.0and CUDA 13.0. - Models: the 20 entries of the
artifactsrole at8da95dfeb, downloaded withhf downloadinto a separate directory. Each directory matched its pinned Hugging Face revision. - Command:
ros2 launch autoware_launch logging_simulator.launch.xml map_path:=$HOME/autoware_data/maps/sample-map-rosbag vehicle_model:=sample_vehicle sensor_model:=sample_sensor_kit data_path:=$HOME/autoware_data/ml_models_1.10.0 - RViz: step 3 of the guide, Target Frame
base_link, applied through a copy ofautoware.rvizwith a closer zoom. - TensorRT built the
lidar_centerpointengines in 7 s and 36 s, and the traffic light engines in 84 s to 365 s. No process died. - Playback:
ros2 bag play ~/autoware_data/recordings/bags/sample-rosbag/ -r 0.2 -s sqlite3exited with code 0. - Localization initialized from GNSS, and the NDT alignment succeeded.
- During the 175 s capture: 299 messages on
/sensing/lidar/concatenated/pointcloud, up to 24 objects on/perception/object_recognition/objects, and up to 13.1 m/s on/localization/kinematic_state. - The screenshot is from 101 s into the capture, with 20 objects and the ego vehicle at 22 km/h.
- Not tested: camera-based traffic light recognition, because the sample bag has no images. Humble was not run.
These run notes are AI generated.
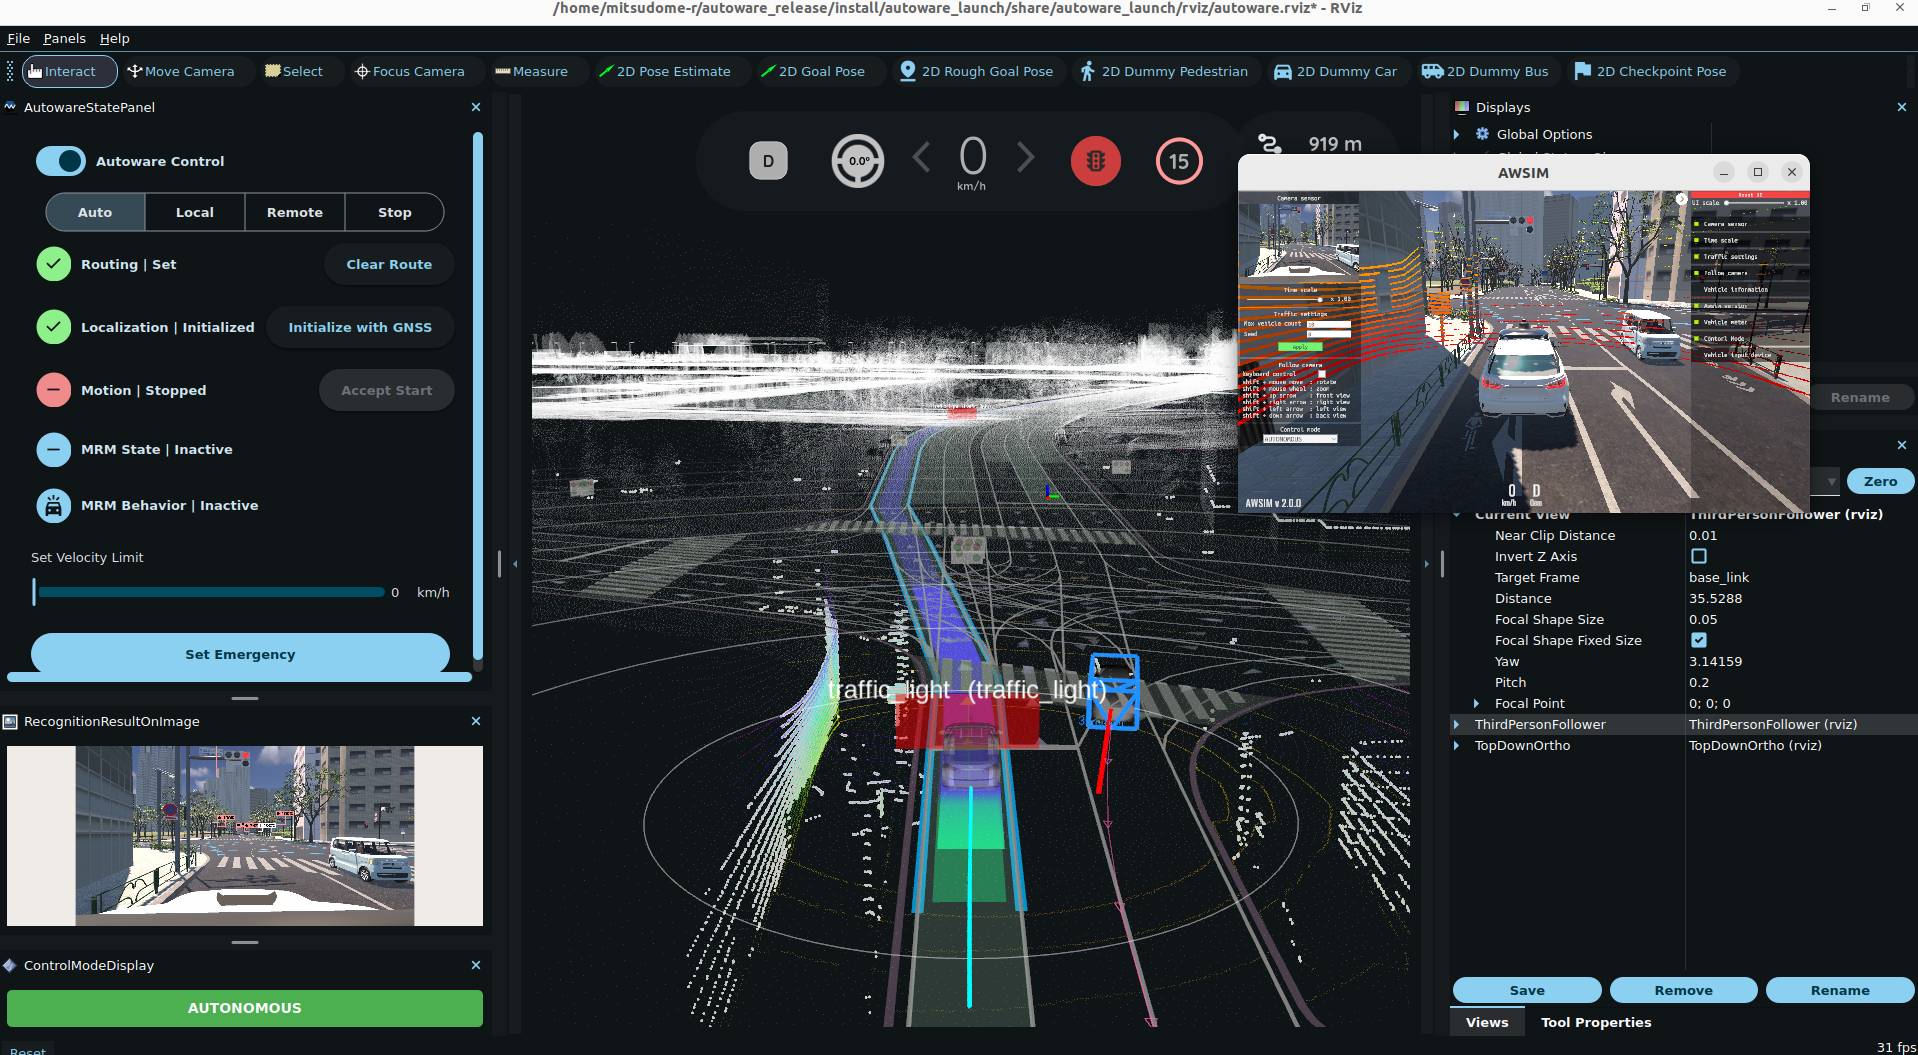
AWSIM

Run notes
- Same workspace, platform and models as the rosbag replay run.
- Simulator:
AWSIM-Demo-Lightweightv2.0.1, the latest AWSIM release. AWSIM started first, as the quick start says. Its window showsAWSIM v 2.0.1. - Map:
Shinjuku-Map.zipfrom the AWSIM v2.0.0 release. Its SHA-256 matched the digest of the release asset. - AWSIM published every topic in the list of the quick start, with the top lidar at 9.9 Hz.
- Command:
ros2 launch autoware_launch e2e_simulator.launch.xml vehicle_model:=sample_vehicle sensor_model:=awsim_sensor_kit map_path:=<map dir> data_path:=$HOME/autoware_data/ml_models_1.10.0 - Localization initialized from GNSS. Traffic light recognition published at 8.3 Hz.
- Route: 461 m with two straight crossings, two left turns and three traffic-light lanelets.
- Result: the route state changed to
ARRIVEDafter 189 s and 452.9 m. The top speed was 4.38 m/s. The vehicle stopped three times on the way, for about 21 s, 16 s and 6 s. I did not record the cause of each stop. - The screenshot is from 163 s after engage, at 15 km/h. The car ahead on the right shows as a detected object with a predicted path.
- Not run here: the HDRP build
AWSIM-Demo, and Humble.
These run notes are AI generated.


Description
Update repository versions in
repositories/autoware.reposfor the Autoware 1.10.0 release.core/autoware_coreuniverse/autoware_universelauncher/autoware_launchHow was this PR tested?
vcs import src < repositories/autoware.reposchecks out every repository at the new versionscolcon buildpasses